Long before modern robotics, inventors and dreamers were already building mechanical beings that pushed the limits of what technology could do. From the early 1900s onward, these machines stepped out of science fiction and into reality, one gear and motor at a time. Writers like Karel Čapek, who coined the word “robot” in his 1920 play “R.U.R. (Rossum’s Universal Robots),” helped fuel public curiosity and inspired a generation of builders. The robots below represent some of the most important milestones in that journey.
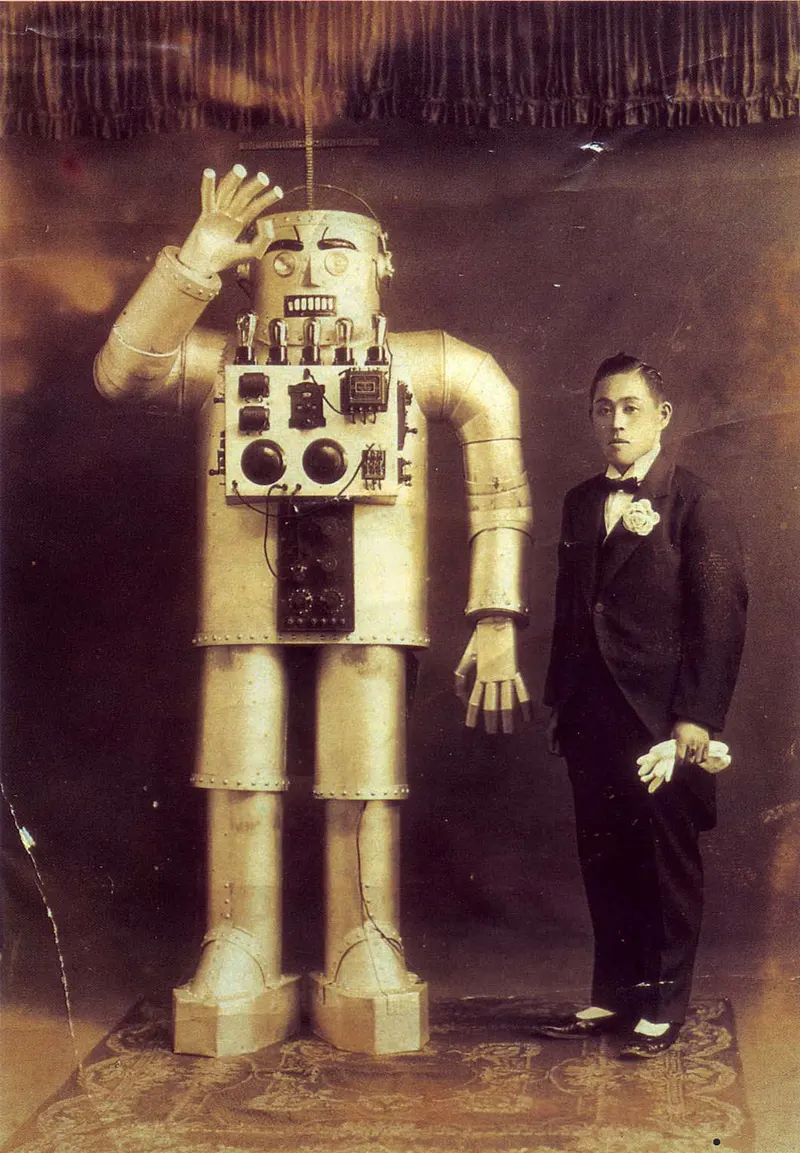
Designed in a humanoid form, this robot was a complex assembly of gears, levers, and motors, capturing the aesthetic and scientific spirit of the early 20th century. Its exterior showcased visible electrical components and valves, intricately integrated into its structure, suggesting a functional purpose but primarily serving an aesthetic role influenced by the artistic sensibilities of the time and the visual style of earlier models like the Televox. The robot’s physical design was carefully crafted to mimic human anatomy, an ambitious goal given the technological limits of the period. Though not advanced in functionality by today’s standards, the robot could perform a series of basic movements, controlled by a rudimentary system that was revolutionary for its time. The simplicity of its controls often concealed the sophistication of the internal mechanisms and the skill required to operate it.
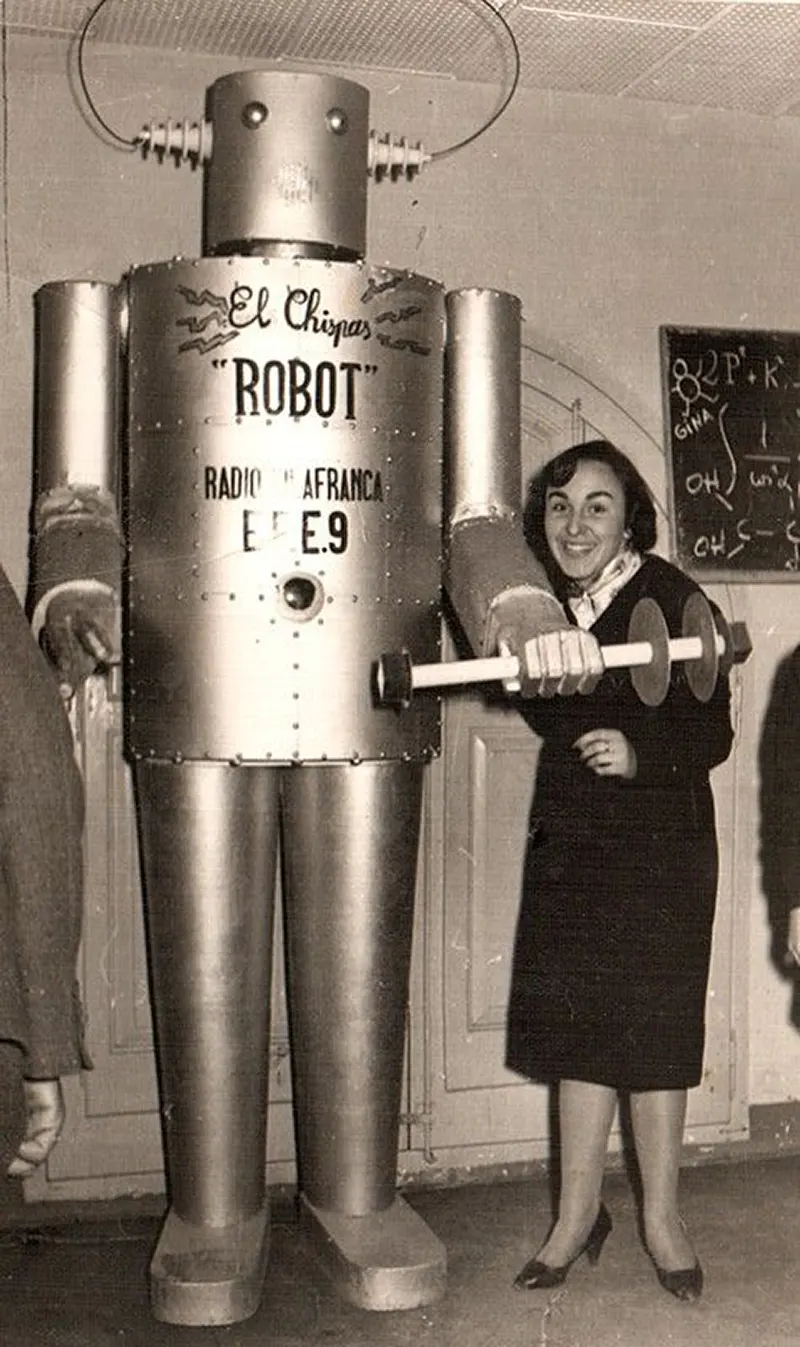
“El Chispas,” built in 1953, was an innovative robot that marked an era of robotic exploration in Spain. This creation came from the collaborative efforts of Antoni Gual Segura and his peers at Radio Vilafranca, and was a spectacle of engineering and creativity for its time. With its humanoid structure, “El Chispas” was primarily built from materials common in radio technology, reflecting the creators’ backgrounds and resourcefulness. One of its most distinctive features was its ability to simulate speech. Although it could not hold conversations, the robot could emit pre-recorded phrases through an internal speaker system. This function, quite advanced for the period, was a source of amazement and represented an early integration of audio technology in robotics. The robot’s physical capabilities included basic arm movements, which, while limited, brought the machine to life in the eyes of observers. These movements were powered by internal motors and operated by direct control, emphasizing the hands-on interaction between “El Chispas” and its operators.
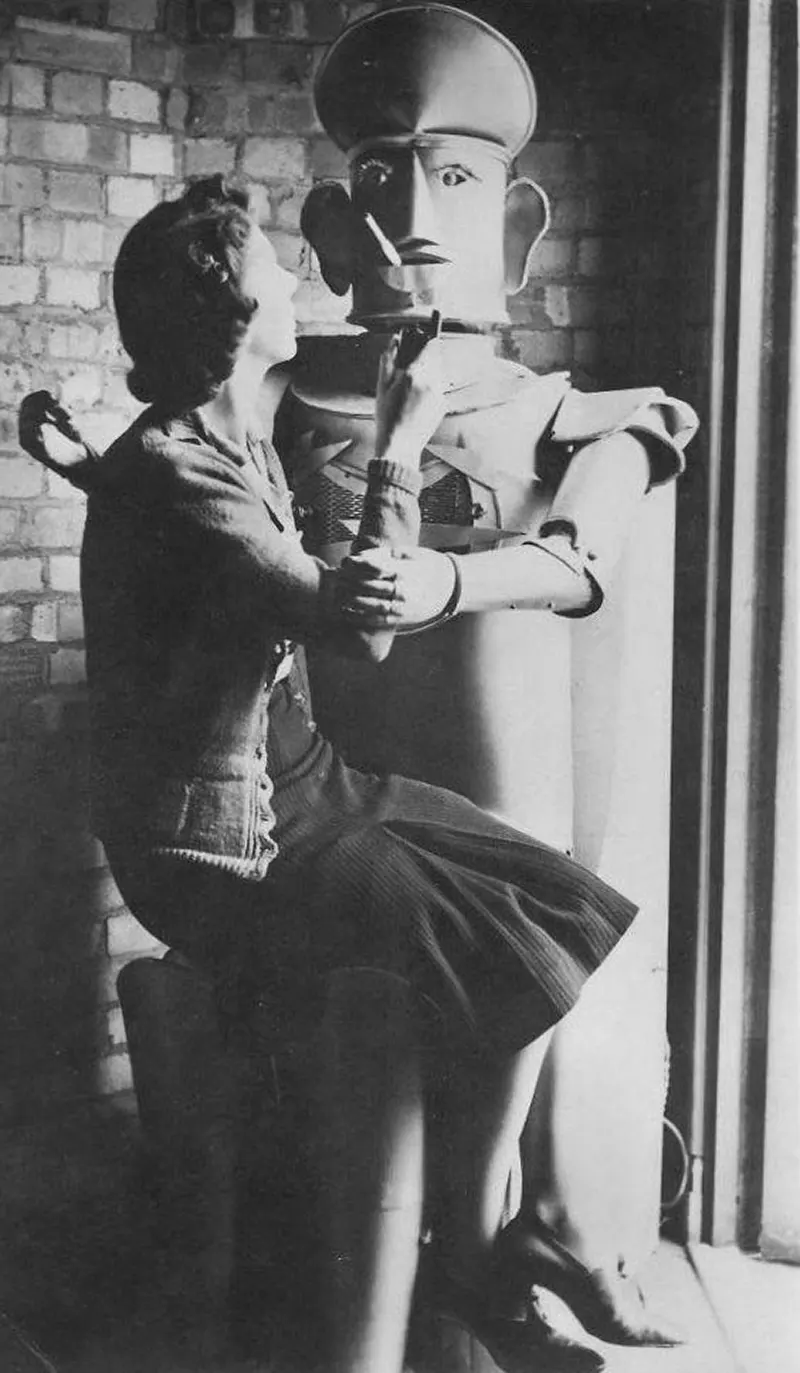
Crafted by inventor Charles Lawson, this 7-foot-tall humanoid robot was an ambitious project that showcased the technological enthusiasm of the era and was designed to interact with the world in ways that seemed futuristic at the time. One of the robot’s key functions was its claimed ability to control traffic. While it did not autonomously manage traffic flow, it could perform simple movements or gestures, using lights or signs to mimic a traffic officer’s signals. This function was particularly symbolic, representing society’s trust in machines and their potential role in maintaining order. “Superman Dennis” was also said to entertain audiences by singing, a feature achieved through phonograph technology or a similar audio playback device installed within. This capability, though not an indication that the robot understood music, displayed early multimedia integration into robotics, turning a machine into a source of public amusement.
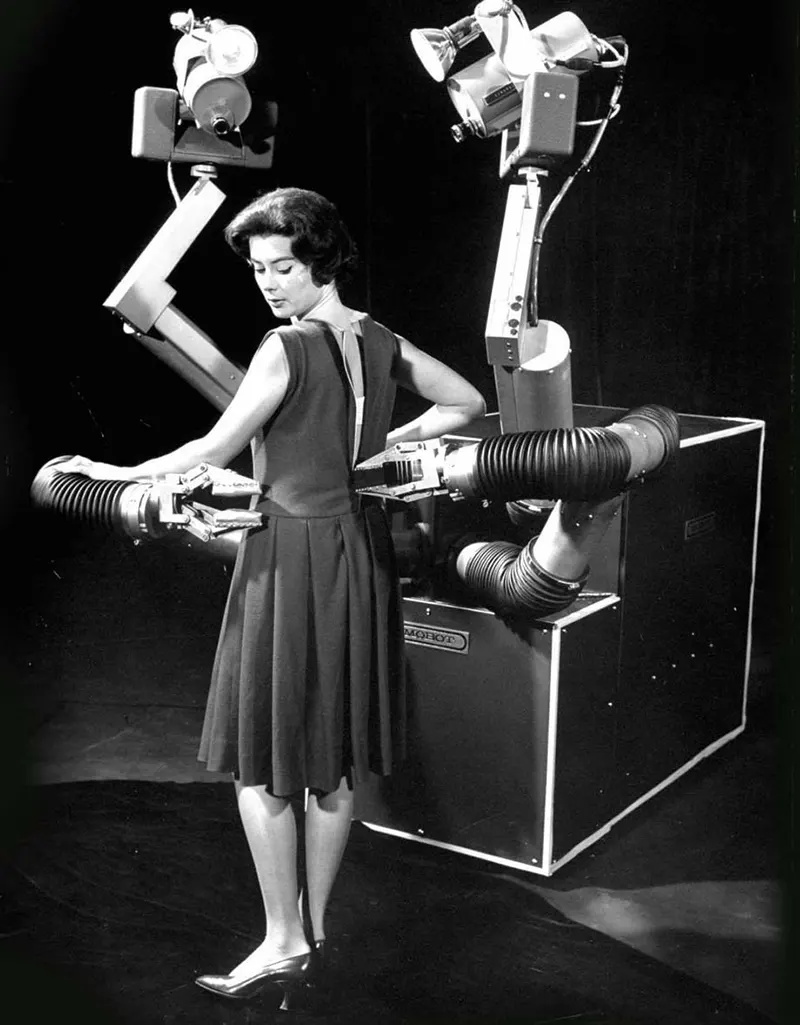
Mobot, introduced in 1961 by Hughes Aircraft Electronic Labs, represented a significant leap in the robotics field during the early 1960s. This large machine, comparable in size to multiple large refrigerators, was an engineering achievement designed to bring the concept of personal robotics closer to everyday life. One of Mobot’s standout features was its promise to automate personal grooming tasks. It was designed to have the dexterity and precision needed for tasks like manicuring, handling a zipper, or assisting with hair combing. These functions would require a high level of fine motor control and responsiveness, an ambitious goal given the technological limits of the time. The intention behind these abilities was to show the potential for robots to take on delicate, precise tasks, pointing toward a future where robotic assistance could extend beyond industry into more personal aspects of daily life.
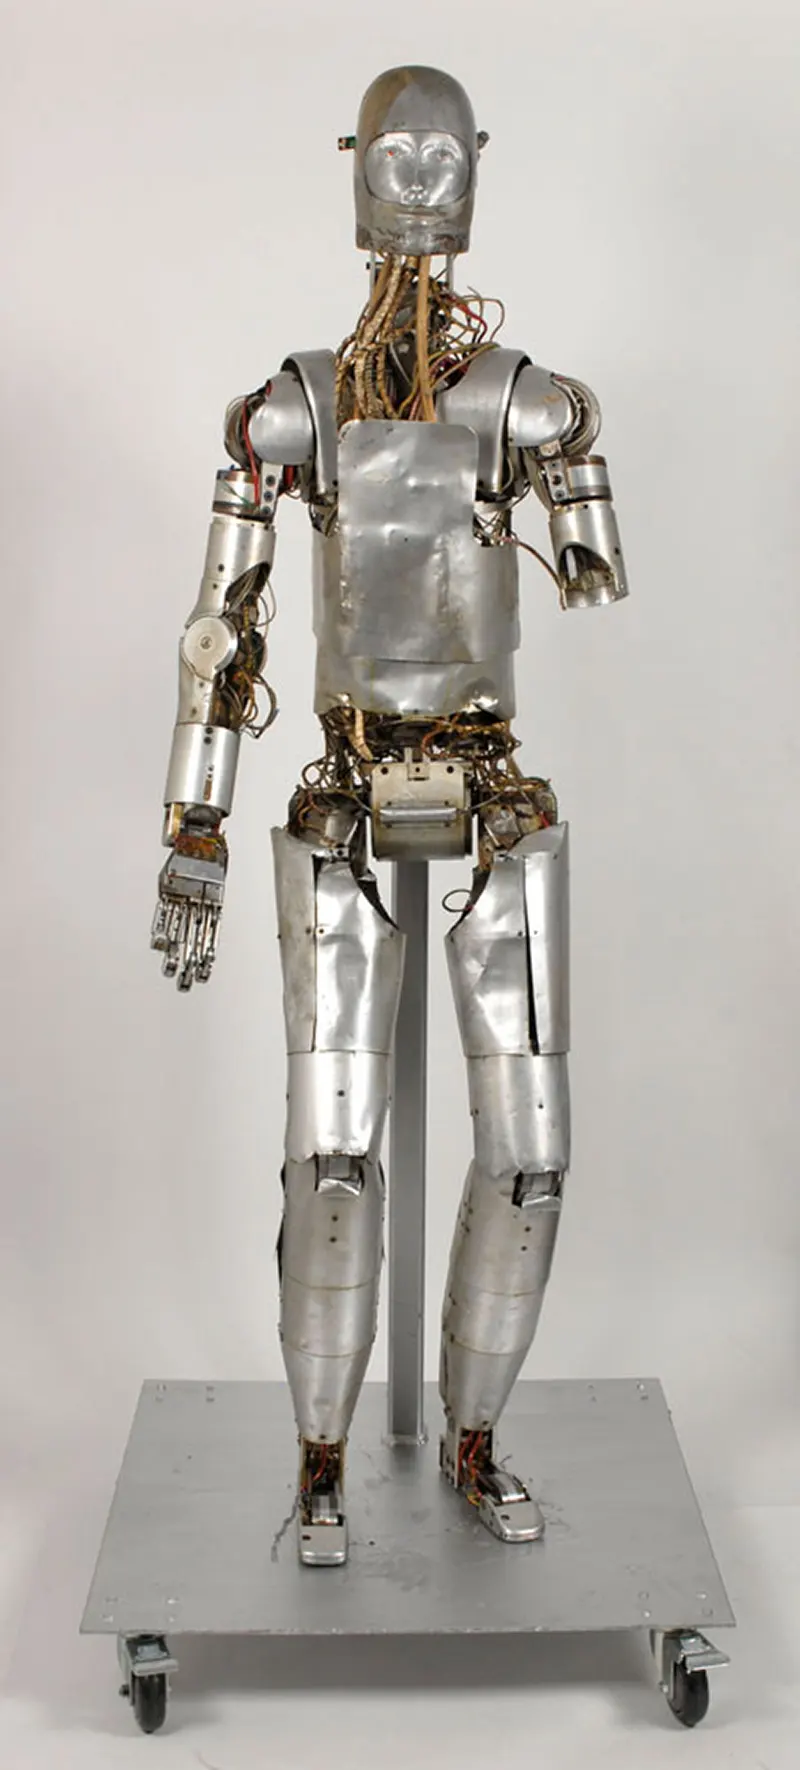
This hydraulic-powered android, developed by the IIT Research Institute in Chicago, was an early example of using machinery to mimic human physiology in order to ensure astronauts’ safety during space missions. The robot, advanced for its time, could simulate 35 basic human motions thanks to its articulated structure. This range of movements allowed NASA to conduct thorough tests on prototype spacesuits under conditions that would replicate an astronaut’s activities in space. The ability to mimic human motions was essential in assessing a suit’s flexibility, resistance, and durability, particularly in environments where traditional testing methods were not sufficient. The robot also featured a sensory system with sensors installed at each joint, allowing the machine to measure the precise forces that a pressurized spacesuit exerted on the body. These measurements were vital for understanding the physical strains astronauts would experience and for making necessary adjustments to spacesuit designs to improve safety and comfort during missions.
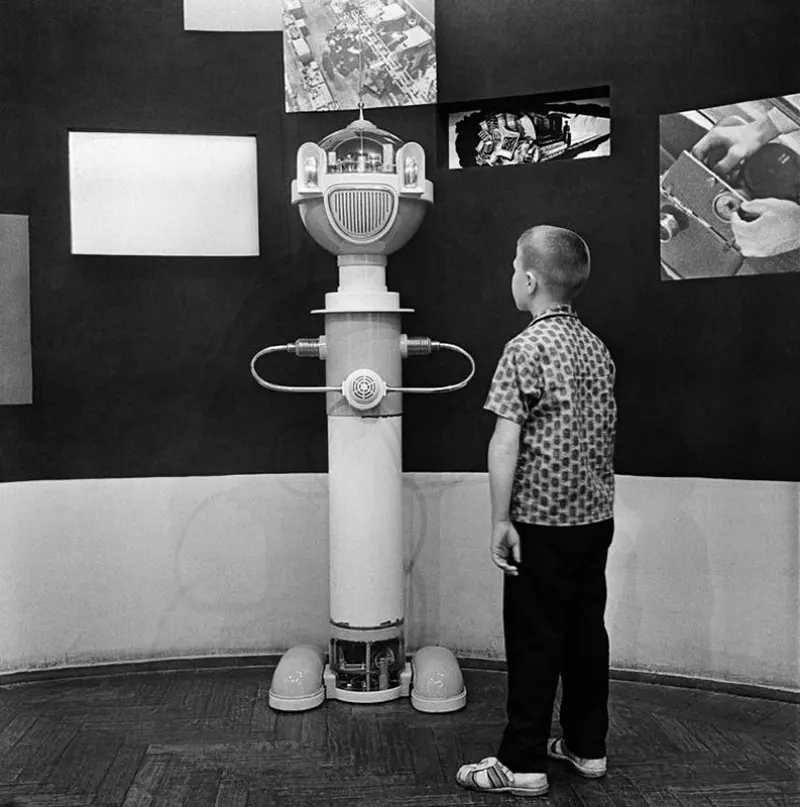
Sepulka, the robotic guide created in 1962 in the Soviet Union, was a notable development in the field of interactive robotics during a period of rapid technological change. Conceived in an experimental workshop of the All-Union Society “Znanie,” designers M. Aleksandrov and art director M. Gorokhov were central to bringing this mechanical figure to life, with its capabilities being notably sophisticated for the era. One of Sepulka’s defining features was its ability to reproduce speech through a built-in tape recorder. This pre-recorded audio allowed Sepulka to communicate with people around it, providing information or guidance in various settings. The use of a tape recorder, while basic compared to modern digital technology, was a practical way to give the robot a voice and make it more relatable to humans. In addition to verbal communication, Sepulka was built with mobility in mind and could be operated via remote radio control from distances of up to 20 meters. This feature allowed operators to direct Sepulka’s movements through different environments and groups of people, including exhibitions and educational demonstrations. The ability to control the robot’s navigation from a distance gave Sepulka a more autonomous appearance during these events.
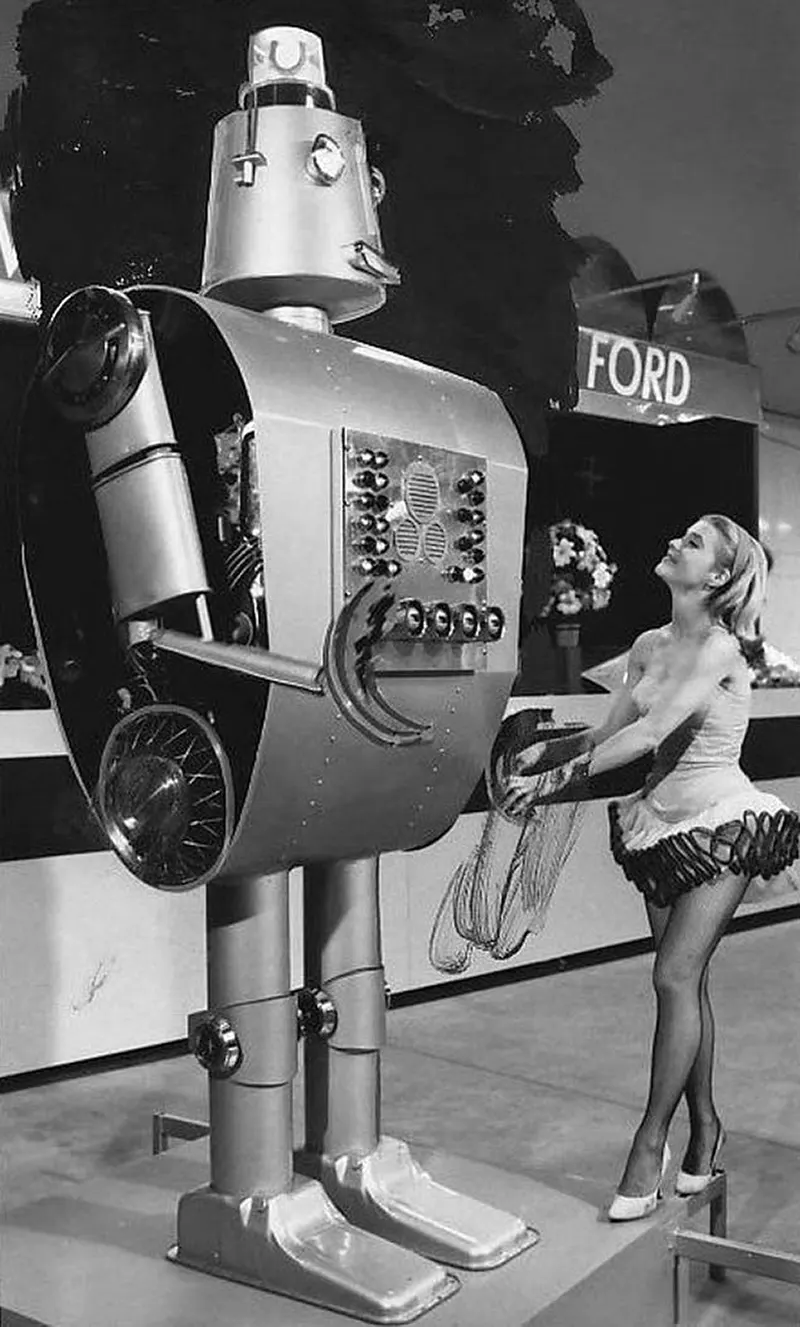
Freddie Ford was a unique promotional robot created in the 1960s, embodying the era’s fascination with robots and the future of automation. What set Freddie apart was his construction: he was a towering nine-foot figure made almost entirely from Ford car parts, representing a creative fusion of automobile engineering and robotic design. His physical characteristics reflected automotive ingenuity, with oil pans serving as feet and brake shoes transformed into hands, suggesting strength and reliability — qualities desirable in both robots and vehicles. His ears were crafted from radiator caps with car antennas, and his eyes were made from Ford Mustang parking lights, giving Freddie a set of sensory organs while keeping the automotive theme intact. The choice of a Ford Thunderbird reversing light for his mouth added character, implying communication ability, though in reality his interactions were limited. Freddie’s mobility was notably restricted, and his primary functions were more performative than practical. His large frame, built with exhaust pipe arms and shock absorber legs, was not designed for flexible movement. Instead, his imposing presence served as a visual spectacle, drawing attention at car shows and helping to promote Ford’s brand and products.
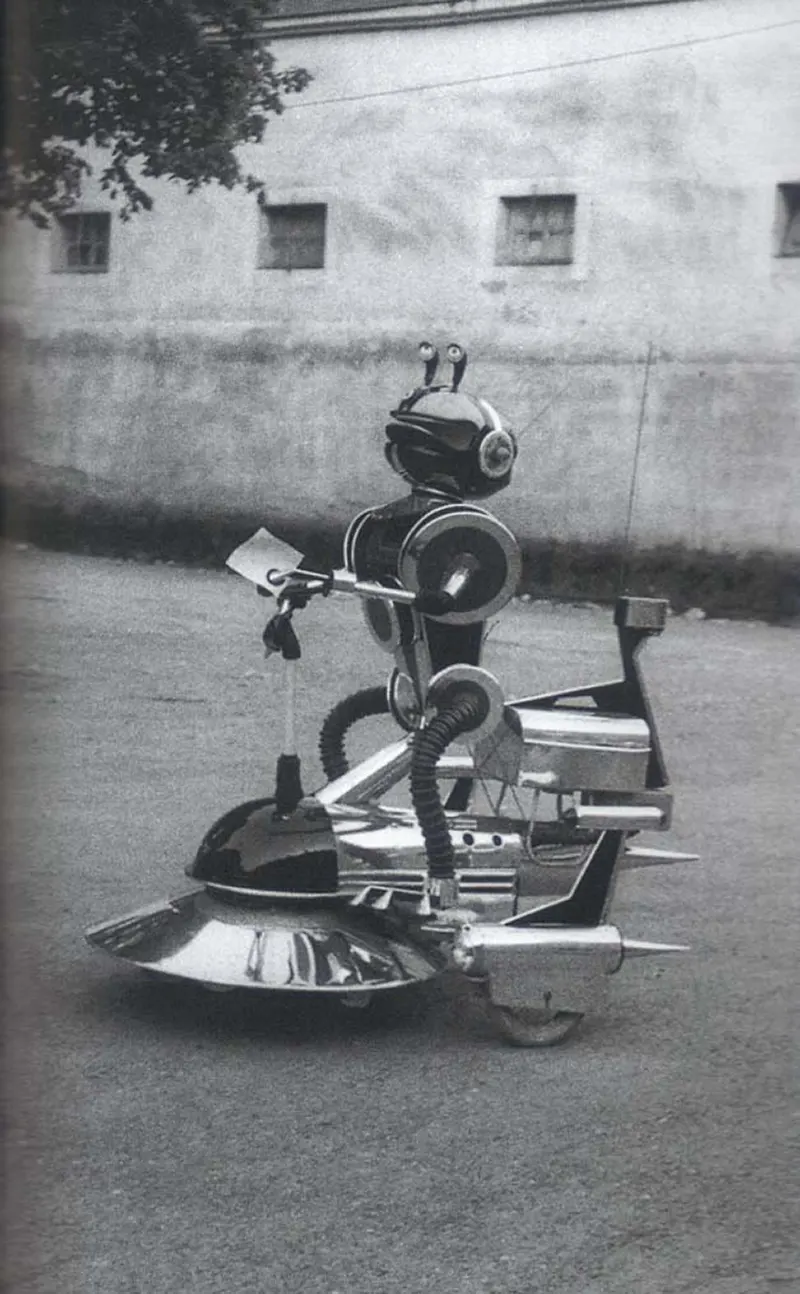
In 1958, France introduced a technological spectacle named “Cosmos,” a robot that captured public attention during a science exhibition along the Seine. This event took place during a period of widespread fascination with space, automation, and futuristic concepts, and “Cosmos” embodied these elements in an engaging way. Constructed with a human-like form, “Cosmos” was not just a static exhibit but was portrayed as capable of driving a vehicle. This was a striking depiction for the time, suggesting a future where automation could rival human skill and precision, even in tasks as complex as driving. The idea of a robot navigating the streets of Paris challenged attendees’ understanding of what technology could do. “Cosmos” was also positioned next to a helicopter within the exhibition, another symbol of cutting-edge technology at the time. This placement offered a dual representation of human ingenuity: a machine that could conquer the skies and one that suggested artificial beings could someday navigate roads. The juxtaposition reflected the era’s forward momentum, with technology pushing the limits of what was possible in every direction.
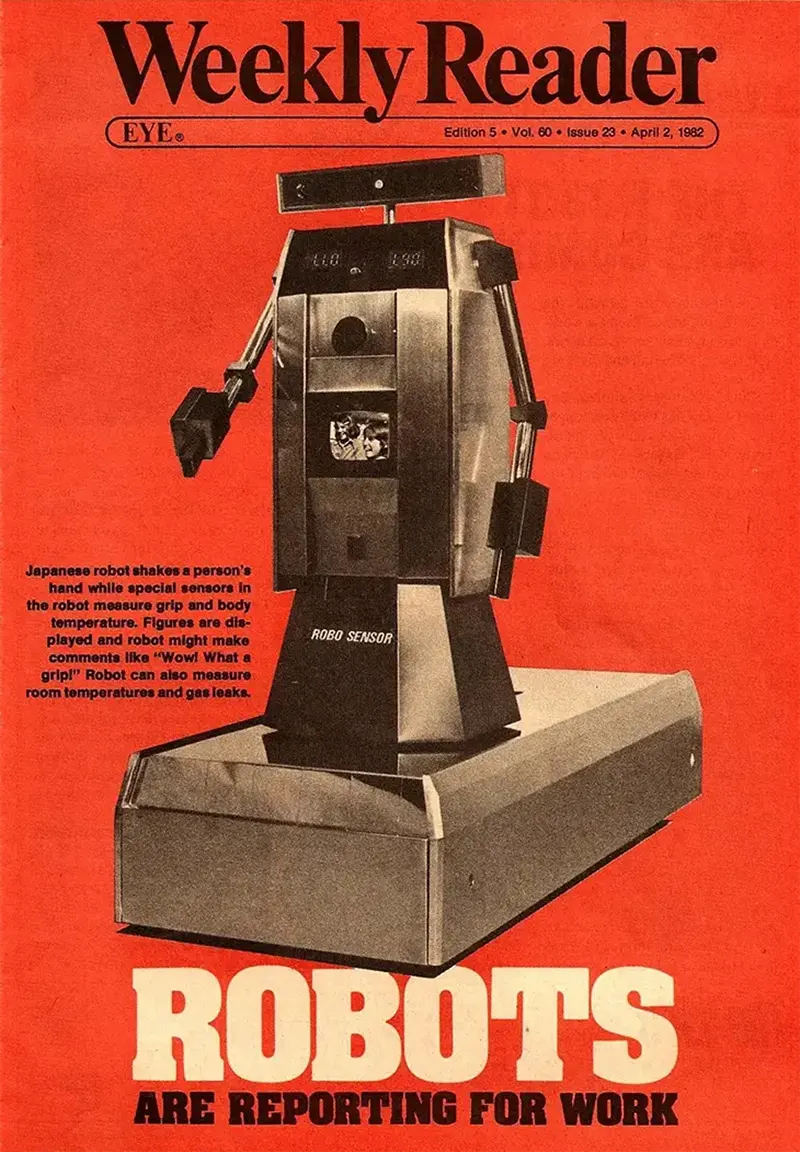
Featured in the Weekly Reader, this Japanese innovation was equipped with special sensors that allowed it to perform tasks beyond basic programmable functions, reflecting the era’s growing interest in intelligent machines. One of Robo Sensor’s notable features was its ability to shake hands with humans. While performing this common social interaction, the robot used its built-in sensors to measure the person’s grip strength and body temperature, displaying those measurements immediately and showcasing an early example of real-time feedback in robotics. The robot was also programmed to respond to the data it collected. For instance, it could comment on the firmness of a person’s handshake with phrases like “WOW, what a grip!” This level of interaction was relatively advanced for the period, pointing toward more personalized and social roles for robots in everyday life. Beyond interpersonal interactions, the Robo Sensor had practical environmental applications. It could measure room temperature, providing ambient awareness useful in household or office settings. More critically, it had the capability to detect gas leaks, a safety feature that highlighted the robot’s utility in preventing potential hazards. This function was particularly significant as an early example of robots being used to monitor environments for conditions that might not be immediately obvious to humans.
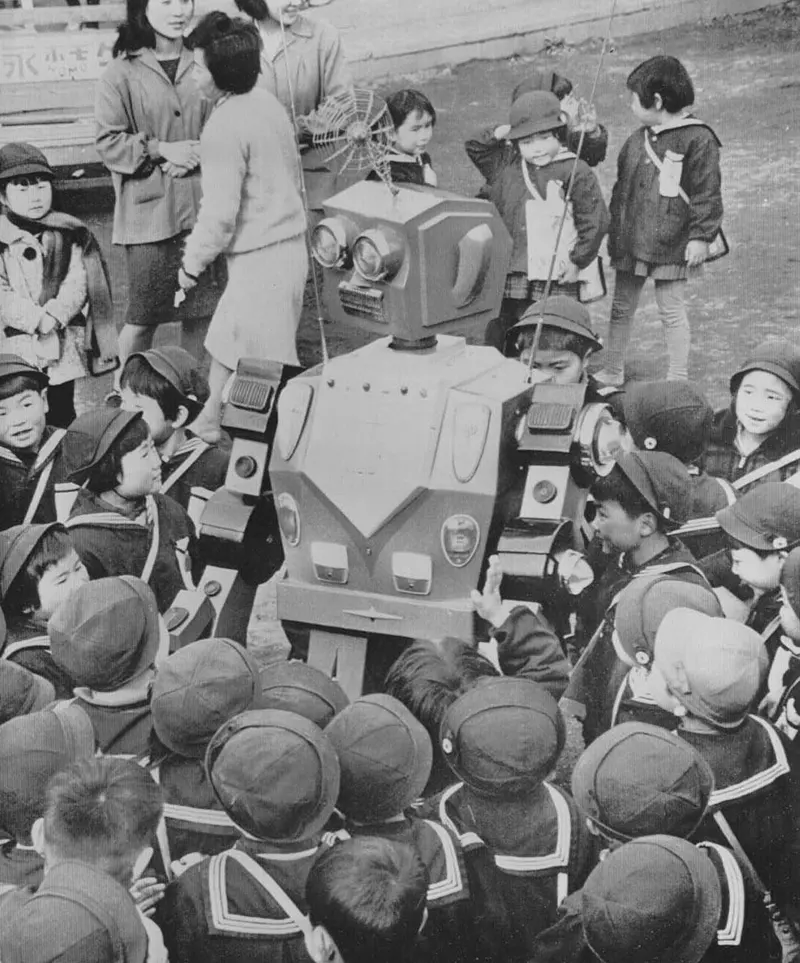
Goro, the robot introduced in Tokyo in 1964, was a notable cultural and technological phenomenon that reflected the era’s fascination with robotics and interactive technology. Developed by a toy research firm, Goro was designed with features that were quite advanced for the time, particularly in its interactions with humans. Standing five feet tall, Goro could walk in all directions. This mobility allowed Goro to engage more naturally with people, moving among them and participating in social environments. While it may have appeared to be a novelty, it represented real advances in motor technology and robotic autonomy within a public setting. Beyond movement, Goro displayed other human-like behaviors. The robot could bow to people it met, a gesture of respect and a common greeting in Japanese culture. This culturally specific behavior indicated a level of social awareness and showed the developers’ intention for Goro to participate meaningfully within a cultural context, not just mimic actions. Goro also had the ability to wink at people, a playful behavior that suggests a programmed set of responses capable of differentiating individuals based on specific characteristics, adding a personal dimension to human-robot interaction.
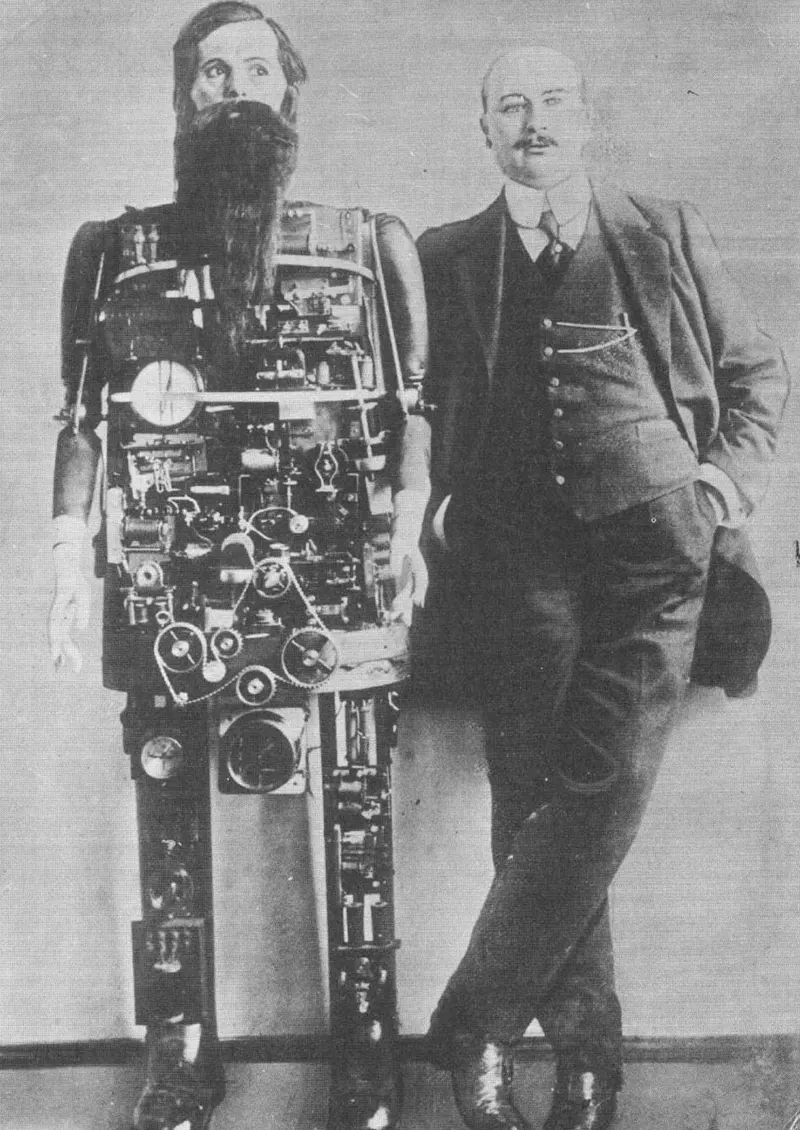
In 1909, a striking invention captured public attention in Berlin: the Barbarossa robot, also referred to as Occultus, crafted by German inventor Herr Adolph Whitman. This early exploration into robotics stood out as a mechanical achievement during a period when even the most basic automation was considered futuristic. Barbarossa was not merely a static display but had a range of human-like functions that were revolutionary for its time. It was designed to walk, a complex task that required advanced engineering to achieve balance, propulsion, and direction. Accomplishing this level of bipedal automation in an era without modern computing was a testament to Whitman’s deep understanding of mechanics. Beyond mobility, Barbarossa could replicate social human interactions. It was built to speak, sing, whistle, and laugh, indicating an early form of audio technology integration, possibly through mechanical phonographs housed within its frame. The ability to mimic these distinctly human actions was a remarkable achievement that pushed the boundaries of what people understood machines could do. Visually, Barbarossa was designed to closely resemble a human. At a short distance, observers could mistake it for a real person, highlighting the level of detail in its external construction. This human-like appearance reflected an early understanding of what would later be known in robotics as the “uncanny valley” — the idea that human replicas can inspire empathy, but when they are too realistic, they can cause discomfort.
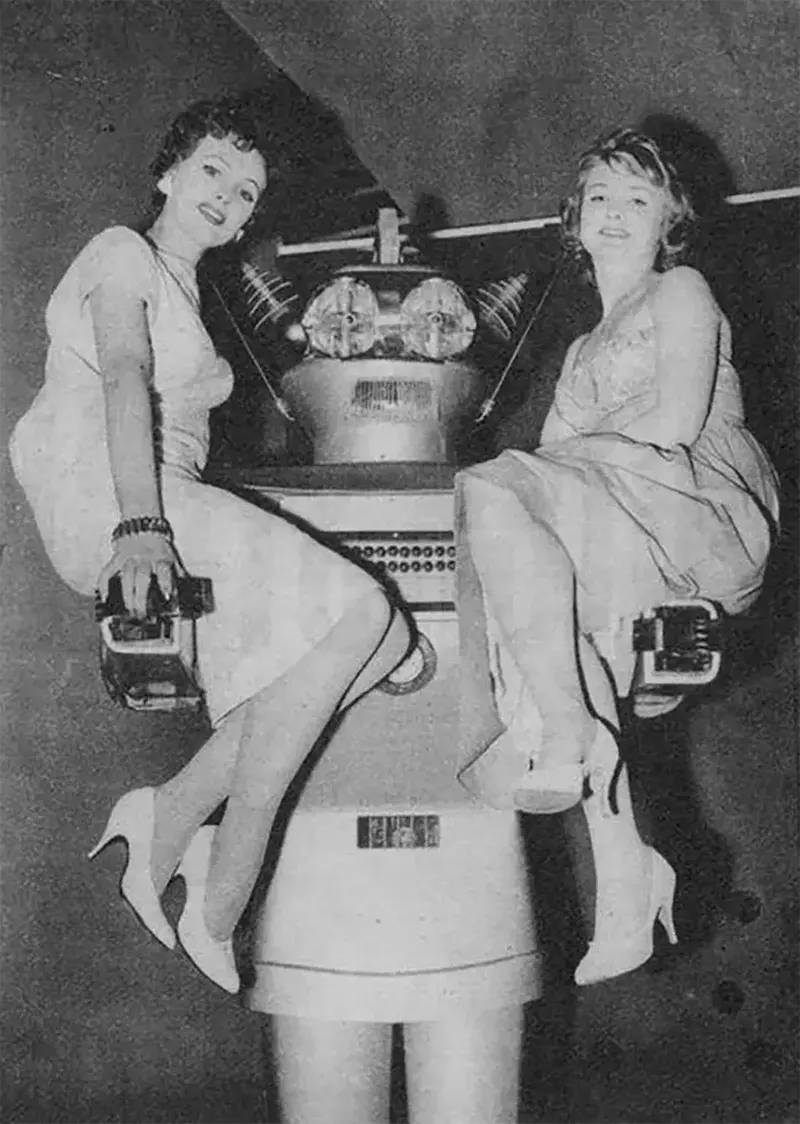
Standing eight feet tall and weighing a substantial 1,000 pounds, Gygan was not just an exhibit but an interactive technological demonstration. Its ability to shuffle forward, at a slow pace of 10 feet per minute, showcased some of the earliest experiments in robotic mobility. This movement, while limited by today’s standards, was a significant achievement at the time, hinting at future possibilities for autonomous machines. Gygan’s features were designed to mimic human-like behaviors, an early example of what would become a standard in humanoid robotics. Its head could turn from left to right, giving it a degree of environmental awareness or the ability to interact with onlookers. The robot’s eyes, resembling car headlamps, would flash, adding to its human-like appearance. These features, while basic, were important first steps in developing machines that could engage with their environment and with people. Controlled via radio, Gygan represented early exploration into remote operation, a feature that remains central in modern robotics, drones, and space exploration vehicles. Remote guidance allowed operators to control Gygan’s movements and interactions, providing a safe and efficient way to demonstrate its capabilities.
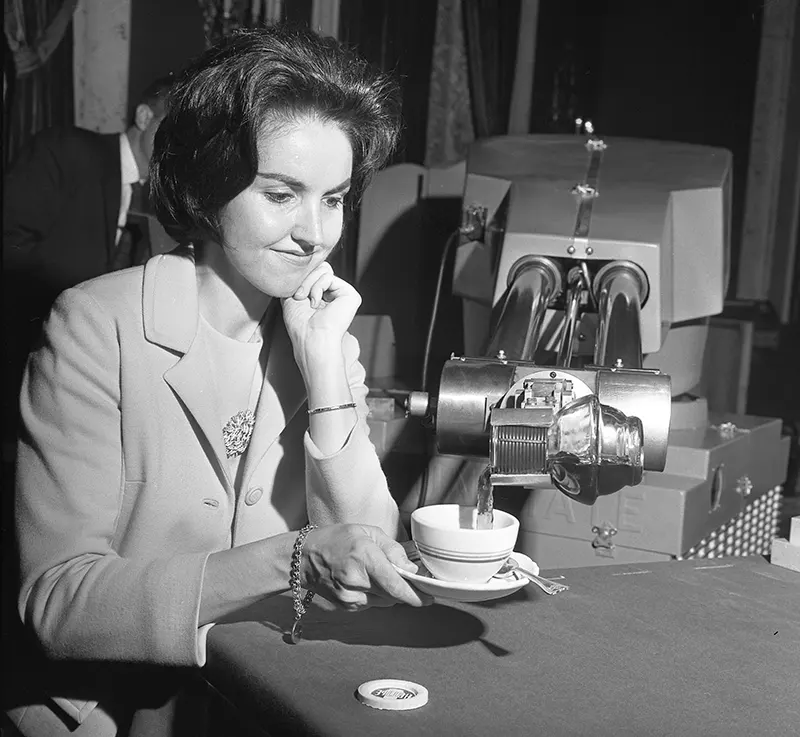
In 1961, the landscape of industrial manufacturing changed with the introduction of the Unimate robot at the General Motors Inland Fisher Guide Plant in Ewing Township, New Jersey. The invention of George Devol, Unimate went beyond previous attempts at automation through its combination of versatility, precision, and reliability, marking a significant step forward in industrial technology. The development of Unimate followed years of careful research by Devol, resulting in a patented invention in the 1950s. The core idea was groundbreaking: an automated machine capable of handling and manipulating equipment in ways previously done only by human hands. This concept opened the door to an entirely new era of industrial automation. Unimate was a programmable manipulator capable of carrying out repetitive and dangerous tasks with consistent precision. It was initially deployed to transport die castings in the manufacturing process, a task that posed serious hazards to human workers due to high temperatures and the risk of physical injury. Unimate could handle these conditions without difficulty, working without interruption and with reliable precision.
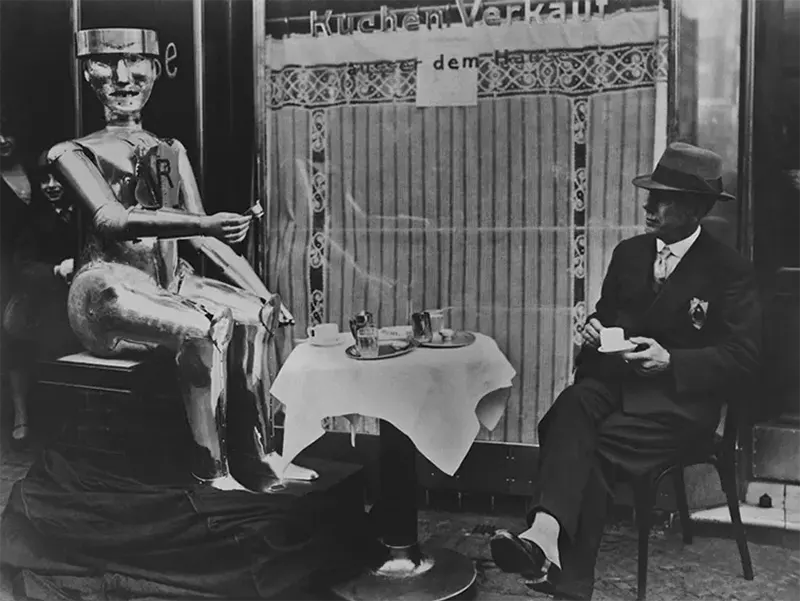
In 1928, a significant event took place in the history of robotics: the introduction of Eric, the first British robot, a pioneering invention by Captain W.H. Richards. Eric was not only a technological achievement of his time but also a cultural figure that captured the public’s imagination. Constructed almost entirely from aluminum, giving him a suitably futuristic look, Eric was more than a static piece of machinery. One of his key mechanical abilities was turning his head, a feature that might seem basic by today’s standards but was a significant achievement in the late 1920s. This capability represented early steps in mimicking human physical movements, an aspect that remains central to humanoid robotics. Another of Eric’s notable skills was his ability to bow, a movement requiring the coordinated operation of multiple parts to carry out what is considered a respectful or ceremonial human gesture. This ability was particularly symbolic, allowing Eric to engage with audiences and dignitaries in a human-like manner, giving a machine a social presence that had not been seen before by the public.
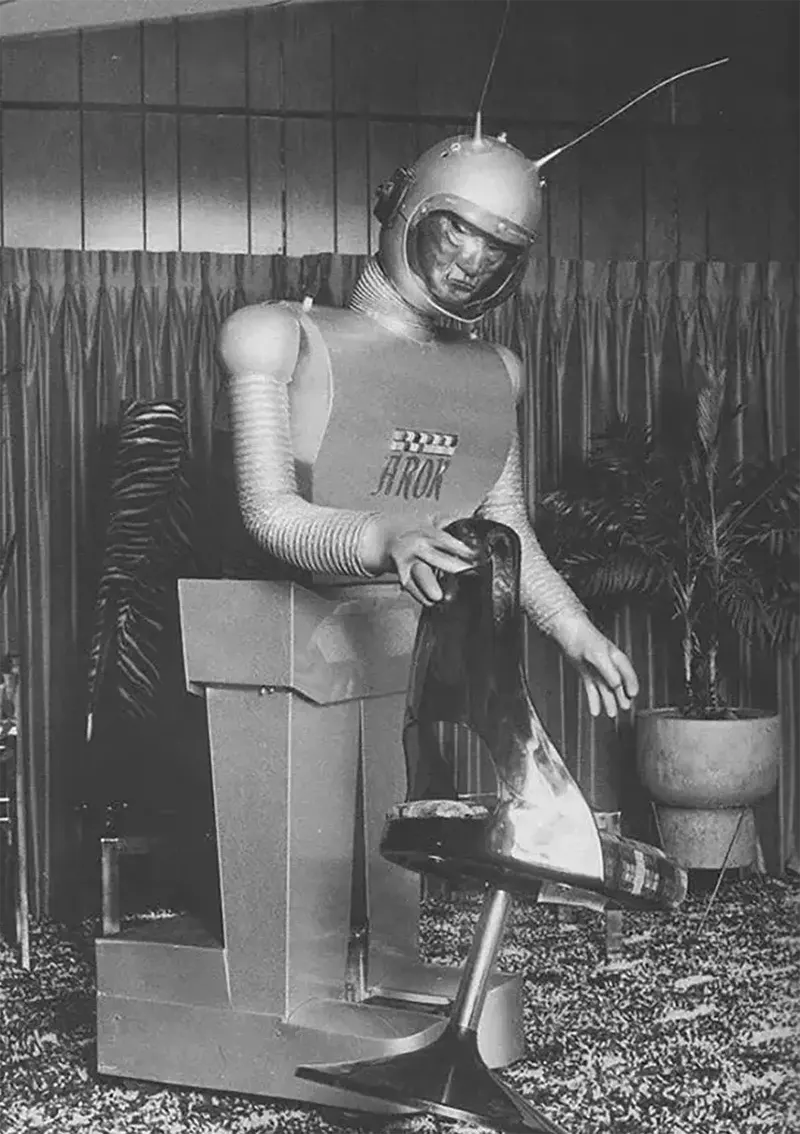
In the early 1970s, a notable advancement in personal robotics came in the form of Arok, a robot created by Ben Skora. Unlike many of its predecessors and contemporaries, Arok was designed for domestic assistance and featured an impressive range of functions that went well beyond the typical expectations for robotics at the time. Arok’s capabilities were diverse and represented a real step forward in personal robotics. The robot could perform household chores, including vacuuming, reflecting early progress in home automation technology. Arok could also mix drinks, showing a level of precision and finesse that pointed to potential applications in hospitality or food service. One of the most interactive aspects of Arok’s design was its ability to engage in simple communication, which represented an early exploration into human-robot interaction. This basic form of social robotics was a precursor to the sophisticated AI-powered social robots seen today. Arok was also equipped with a camera system, allowing it to take photos — an early sign of integrating robotics with other technologies and hinting at potential uses in surveillance or documentation. The robot could also lift objects weighing up to 150 pounds, demonstrating its usefulness in heavy-lifting tasks that could be challenging or dangerous for humans.
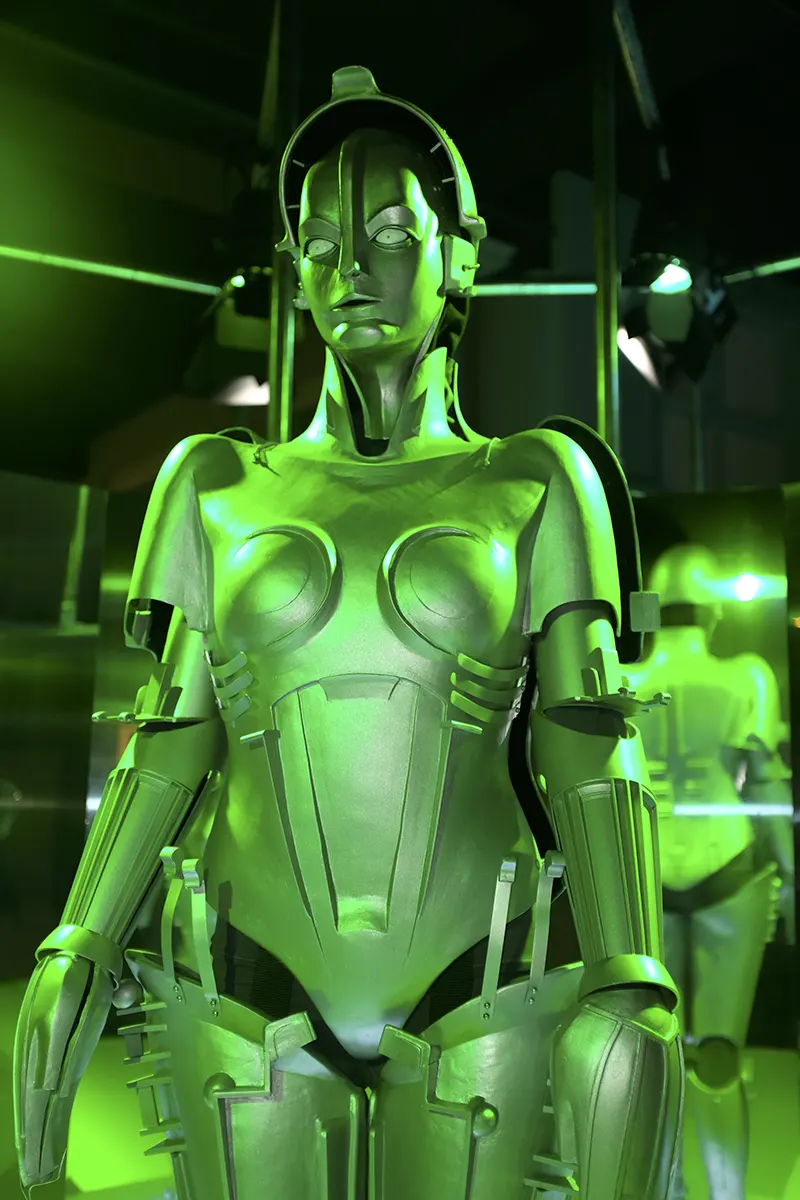
In 1927, the cinematic world was introduced to one of the most iconic figures in science fiction: the robot Maria from Fritz Lang’s groundbreaking film “Metropolis.” This character was more than a robot — Maria stood as a symbol of both the potential and the dangers of technology during an era defined by industrial change. Maria’s design was revolutionary for the time. Built to mimic the form of a human woman, her art deco-inspired appearance blurred the line between a mechanical aesthetic and human resemblance, challenging audiences to see humanity within the machine. Her metallic, gleaming surface, made up of plates and gears, maintained the impression of something manufactured, while lifelike movements and expressions created an unsettling contrast with her clearly artificial origins. In “Metropolis,” Maria serves a complex narrative role. She is not merely a display of technological power but is central to the film’s plot, embodying themes of deception, class conflict, and the misuse of technology. Created by the scientist Rotwang, the robot Maria is a replica of the protagonist Maria, who inspires and leads the city’s workers. The robot’s purpose — to create division among the working class — illustrates a central theme of the film: technology as a tool for control and oppression. This was a pointed message that spoke directly to industrial-age anxieties. Maria’s character was also a feat of early special effects. The transformation scene, in which the robot takes on Maria’s appearance, used pioneering filmmaking techniques that amazed audiences and set a precedent for visual effects in cinema. This sequence, highlighting the duality between human and machine, became one of the most remembered in film history.